
 Bahasa Indonesia
 Deutsch
 English
 Français
 Português (Brasil)
 Türkçe
 ไทย
 中文(简体)
 中文(繁體)
 日本語
 한국어
Cámara RGB
La cámara da una imagen de lo que tiene delante. La necesitas para encontrar y leer las marcas en las paredes. El robot inicial tiene una cámara, llamada camera, de 64 × 40 píxeles.
Leer píxeles
Sección titulada «Leer píxeles»Una imagen es una cuadrícula de píxeles. Cada uno tiene un valor de rojo, verde y azul de 0 a 255, donde (0, 0, 0) es negro y (255, 255, 255) es blanco.
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)width = camera.getWidth()height = camera.getHeight()print("The camera has", width, "x", height, "pixels")
while robot.step(timeStep) != -1:    image = camera.getImage()    # The colour of the pixel in the center of the image    r = camera.imageGetRed(image, width, width // 2, height // 2)    g = camera.imageGetGreen(image, width, width // 2, height // 2)    b = camera.imageGetBlue(image, width, width // 2, height // 2)    print("Center:", r, g, b)
#include <iostream>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep); int width = camera->getWidth(); int height = camera->getHeight(); cout << "The camera has " << width << " x " << height << " pixels" << endl;
while (robot->step(timeStep) != -1) { const unsigned char *image = camera->getImage(); // The colour of the pixel in the center of the image int r = Camera::imageGetRed(image, width, width / 2, height / 2); int g = Camera::imageGetGreen(image, width, width / 2, height / 2); int b = Camera::imageGetBlue(image, width, width / 2, height / 2); cout << "Center: " << r << " " << g << " " << b << endl; }
delete robot; return 0;}Usar OpenCV
Sección titulada «Usar OpenCV»OpenCV es una biblioteca para procesar imágenes: encontrar formas, comparar colores y mucho más. Las imágenes de Webots tienen 4 valores por píxel, en orden BGRA, que OpenCV puede usar directamente. Este programa muestra la imagen, y sus partes brillantes, en dos ventanas:
from controller import Robotimport cv2import numpy as np
robot = Robot()timeStep = int(robot.getBasicTimeStep())
camera = robot.getDevice("camera")camera.enable(timeStep)
while robot.step(timeStep) != -1:    # Webots images have 4 channels per pixel, in BGRA order    image = np.frombuffer(camera.getImage(), np.uint8).reshape((camera.getHeight(), camera.getWidth(), 4))    frame = cv2.cvtColor(image, cv2.COLOR_BGRA2BGR)    gray = cv2.cvtColor(frame, cv2.COLOR_BGR2GRAY)    _, thresh = cv2.threshold(gray, 200, 255, cv2.THRESH_BINARY)  # Bright parts in white
    cv2.imshow("camera", cv2.resize(frame, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.imshow("threshold", cv2.resize(thresh, None, fx=4, fy=4, interpolation=cv2.INTER_NEAREST))    cv2.waitKey(1)  # Shows the windows
#include <opencv2/opencv.hpp>#include <webots/Robot.hpp>#include <webots/Camera.hpp>
using namespace webots;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
Camera *camera = robot->getCamera("camera"); camera->enable(timeStep);
while (robot->step(timeStep) != -1) { // Webots images have 4 channels per pixel, in BGRA order cv::Mat image(camera->getHeight(), camera->getWidth(), CV_8UC4, (void *)camera->getImage()); cv::Mat frame, gray, thresh; cv::cvtColor(image, frame, cv::COLOR_BGRA2BGR); cv::cvtColor(frame, gray, cv::COLOR_BGR2GRAY); cv::threshold(gray, thresh, 200, 255, cv::THRESH_BINARY); // Bright parts in white
cv::Mat big; cv::resize(frame, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("camera", big); cv::resize(thresh, big, cv::Size(), 4, 4, cv::INTER_NEAREST); cv::imshow("threshold", big); cv::waitKey(1); // Shows the windows }
delete robot; return 0;}A la izquierda, una imagen de la cámara del robot inicial delante de una víctima de letra. A la derecha, sus partes brillantes, tal como las encuentra este programa.
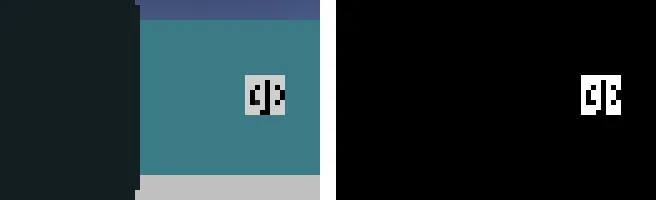
Ventanas como estas son para hacer pruebas en casa: desactívalas para la competición.
Resolución
Sección titulada «Resolución»Las resoluciones más altas ven las marcas desde más lejos, pero cuestan más y tardan más en procesarse. Eliges la resolución de cada cámara en el Robot Customizer.
Erebus forma parte de RoboCupJunior Rescue.
Noticias, eventos y documentos de equipos: sitio web de la comunidad RCJ Rescue
© 2020–2026 Erebus Development Team