
 Deutsch
 English
 Español
 Français
 Português (Brasil)
 Türkçe
 ไทย
 中文(简体)
 中文(繁體)
 日本語
 한국어
Ini adalah dokumentasi untuk Erebus v26, yang bukan lagi versi terbaru.Lihat dokumentasi terbaru
Sensor jarak
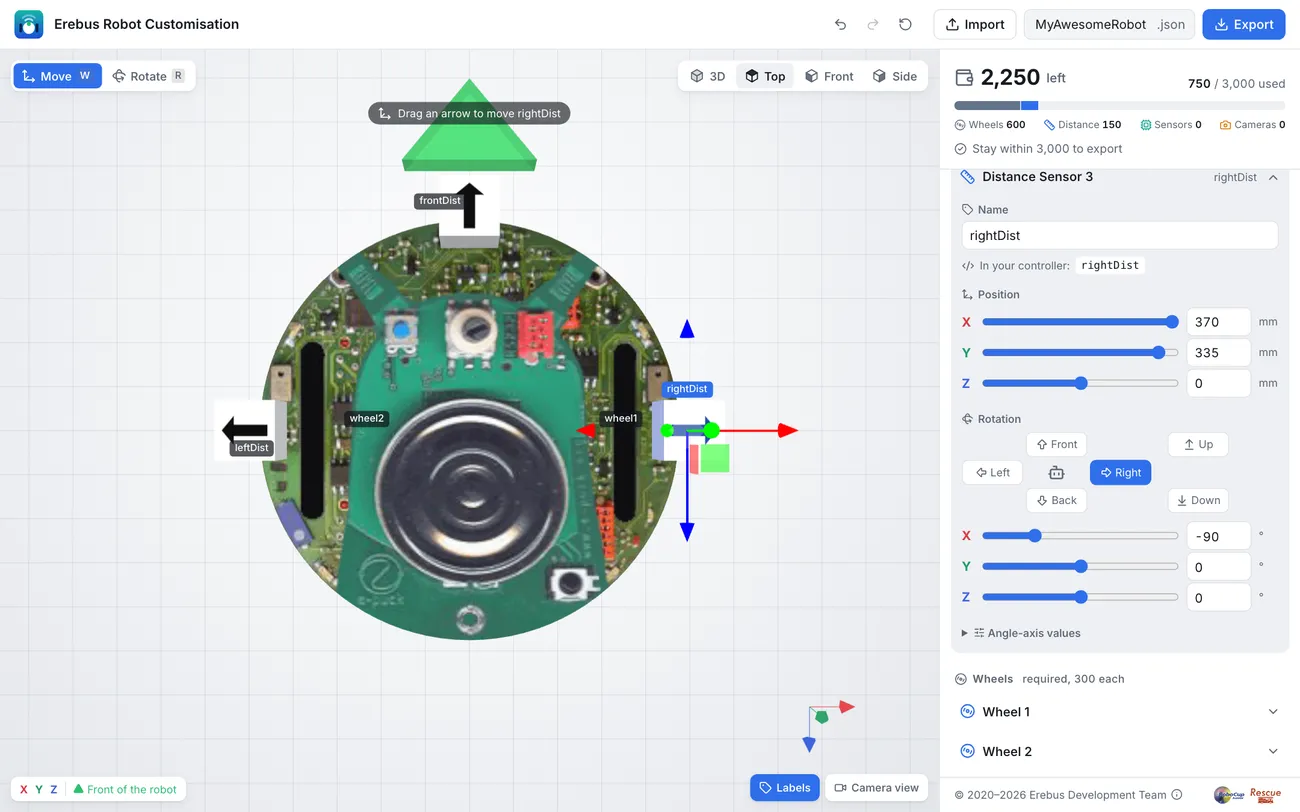
Sensor jarak mengukur jarak, dalam meter, ke benda pertama di depannya, hingga 0,8 m. Robot pemula punya tiga sensor: leftDist, frontDist, dan rightDist, yang menghadap ke kiri, depan, dan kanan.
Membaca sensor
Section titled “Membaca sensor”from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
frontDist = robot.getDevice("frontDist") # Get the sensor by namefrontDist.enable(timeStep) # Enable it
while robot.step(timeStep) != -1: print("Front:", round(frontDist.getValue(), 3), "m")#include <iostream>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
DistanceSensor *frontDist = robot->getDistanceSensor("frontDist"); // Get the sensor by name frontDist->enable(timeStep); // Enable it
while (robot->step(timeStep) != -1) cout << "Front: " << frontDist->getValue() << " m" << endl;
delete robot; return 0;}Menemukan dinding
Section titled “Menemukan dinding”Lebar satu ubin adalah 12 cm, jadi saat robot berada di tengah ubin, dinding di sampingnya berjarak sekitar 5 cm. Program ini memeriksa ketiga sensor, lalu mencetak sensor mana yang melihat dinding:
from controller import Robot
robot = Robot()timeStep = int(robot.getBasicTimeStep())
# Keep the sensors in a dictionary, to use them by namesensors = {}for name in ["leftDist", "frontDist", "rightDist"]:    sensors[name] = robot.getDevice(name)    sensors[name].enable(timeStep)
WALL = 0.07  # Closer than 7 cm counts as a wall next to the robot
while robot.step(timeStep) != -1:    walls = [name for name, sensor in sensors.items() if sensor.getValue() < WALL]    print("Walls:", walls)
#include <iostream>#include <string>#include <vector>#include <webots/Robot.hpp>#include <webots/DistanceSensor.hpp>
using namespace webots;using namespace std;
int main() { Robot *robot = new Robot(); int timeStep = (int)robot->getBasicTimeStep();
vector<string> names = {"leftDist", "frontDist", "rightDist"}; vector<DistanceSensor *> sensors; for (const string &name : names) { sensors.push_back(robot->getDistanceSensor(name)); sensors.back()->enable(timeStep); }
const double WALL = 0.07; // Closer than 7 cm counts as a wall next to the robot
while (robot->step(timeStep) != -1) { cout << "Walls:"; for (size_t i = 0; i < sensors.size(); i++) if (sensors[i]->getValue() < WALL) cout << " " << names[i]; cout << endl; }
delete robot; return 0;}Sensor mengukur dari posisinya di robot, bukan dari tengah robot. Cetak nilainya saat robot berada di dekat dinding untuk menentukan nilai ambangmu sendiri.
Erebus adalah bagian dari RoboCupJunior Rescue.
Berita, acara, dan dokumen tim: Situs Web Komunitas RCJ Rescue
© 2020–2026 Erebus Development Team